Parametric Arc Length Calculator
A parametric arc length calculator measures the distance traveled along a curve defined by x(t) and y(t) over a parameter interval from t = a to t = b.
Original Curve & Selected Arc
Gold dots mark the midpoint of each subinterval.
Integrand g(x) & Midpoint Rectangles
Hover a rectangle for its subinterval, midpoint, integrand value and contribution.
Detailed Midpoint Calculation Table
Convergence Comparison
Differences between successive refinements are a practical error indicator, not a guaranteed error bound.
Calculation Error
Section Navigation
How to Use the Parametric Arc Length Calculator
Using the calculator takes less than a minute once you know what each field expects. Follow these steps in order.
- Enter the x(t) equation. Type the horizontal component as a function of t, for example
5*cos(t). Use*for multiplication,^for powers, and parentheses to group expressions. - Enter the y(t) equation. Type the vertical component the same way, for example
5*sin(t). - Set the starting parameter value. This is the lower bound a, the t-value where measurement begins. It can be a number like
0or an expression likeπ/2. - Set the ending parameter value. This is the upper bound b, where measurement stops. The calculator assumes b is greater than a for a forward traversal.
- Check your syntax. Write
πfor π, usesin(t),cos(t),tan(t),√(t), andexp(t)for standard functions. Avoid implicit multiplication like5t; write5*tinstead. - Calculate. Press the calculate button. The tool differentiates both components, forms the speed expression, and evaluates the definite ∫.
- Interpret the result. The output is the total distance along the curve in the same coordinate units as your x and y values. If available, review the step-by-step breakdown to see the derivative, integrand, and integration stages.
Quick example to try: enter x(t) = 5*cos(t), y(t) = 5*sin(t), start t = 0, end t = π/2. The calculator returns approximately 7.854, which is one quarter of a circle with radius 5.
What Is the Arc Length of a Parametric Curve?
Parametric equations describe a curve using a third variable, usually called the parameter t. Instead of writing y directly as a function of x, you write both coordinates as functions of t: x(t) gives the horizontal position and y(t) gives the vertical position at each parameter value. As t increases from a to b, the point (x(t), y(t)) moves along the curve, tracing out its shape.
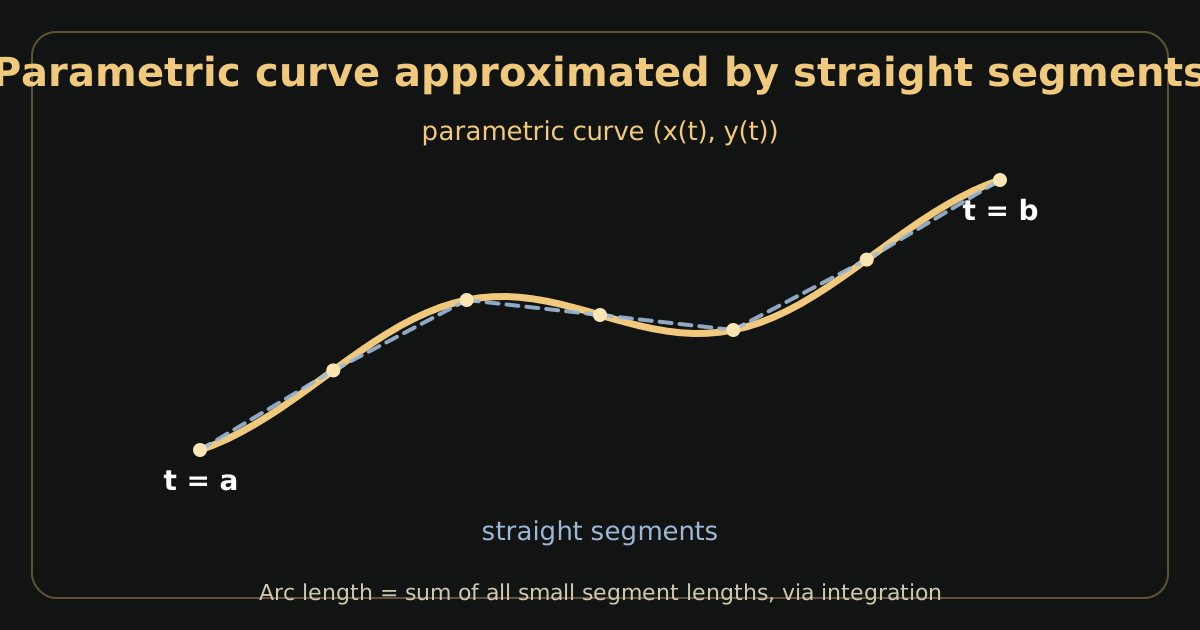
The parameter does not always represent physical time. It is simply an index that orders the points along the curve. In a circle parameterized by x(t) = r·cos(t) and y(t) = r·sin(t), the parameter t happens to equal the angle, but in general t can be any convenient variable.
Now consider the difference between displacement and path length. Displacement is the straight-line distance between the start point and the end point. Path length, or arc length, is the total distance actually traveled along the curve. Picture a delivery robot that drives from a warehouse to a house along a winding road. The straight-line distance on a map might be 2 kilometers, but the robot's odometer reads 3.5 kilometers because the road curves. Arc length is the odometer reading.
The ordinary distance formula only handles straight segments, so it cannot measure a curved path directly. Calculus solves this by breaking the curve into tiny pieces, treating each piece as nearly straight, and adding up all the small lengths through integration.
Parametric Arc Length Formula Explained
For a smooth parametric curve defined by x(t) and y(t) on the interval [a, b], the arc length is:
Each symbol has a specific meaning:
- L: the total arc length, always a nonnegative number.
- x(t): the horizontal position as a function of the parameter.
- y(t): the vertical position as a function of the parameter.
- t: the parameter, the independent variable that sweeps out the curve.
- a and b: the starting and ending parameter values, with a < b for forward motion.
- dx/dt: how fast the x-coordinate changes as t changes.
- dy/dt: how fast the y-coordinate changes as t changes.
- The square-root expression: the magnitude of the derivative vector (dx/dt, dy/dt), which is the instantaneous speed of the moving point.
Both derivatives are squared and added because of the Pythagorean theorem. At any instant, the point moves a little bit horizontally and a little bit vertically; the actual distance it covers in that instant is the hypotenuse of those two small displacements. Squaring removes sign information (moving left counts the same as moving right), and the square root converts the sum back into a length.
How Is the Parametric Arc Length Formula Derived?
The formula comes from a simple geometric idea applied on a very small scale. Here is the reasoning step by step.
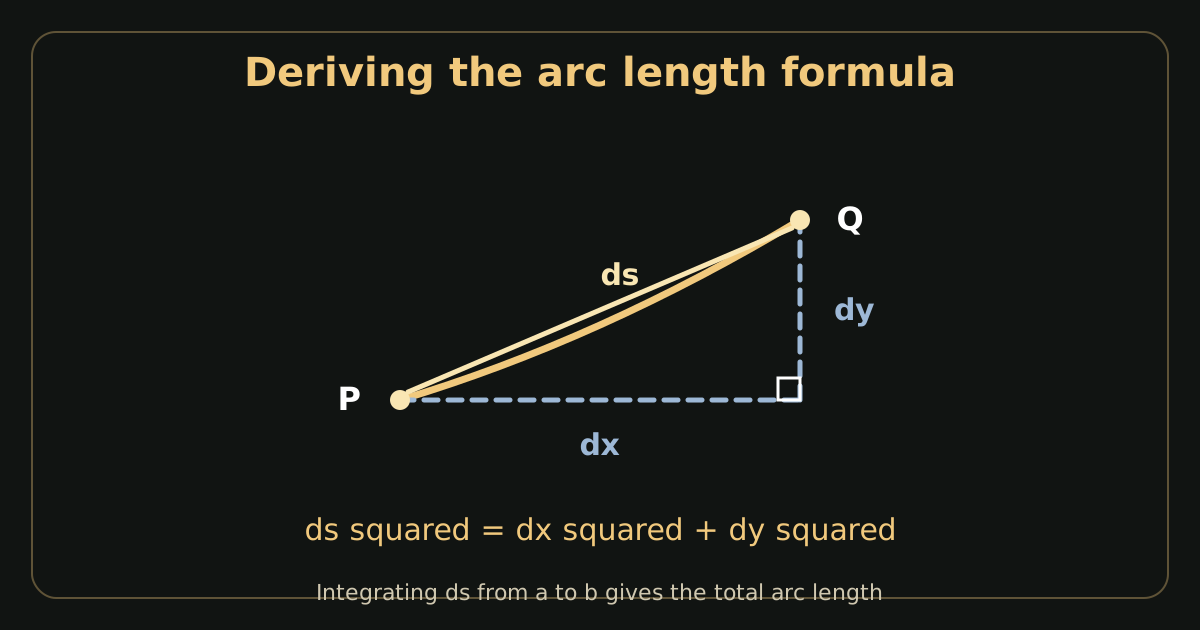
Step 1: Pick two nearby points. Choose parameter values t and t + Δt that are very close together. The corresponding curve points are P = (x(t), y(t)) and Q = (x(t + Δt), y(t + Δt)).
Step 2: Approximate with a straight segment. When Δt is tiny, the curve between P and Q is nearly straight, so the segment PQ is a good approximation of the true curve length there.
Step 3: Apply the Pythagorean theorem. The horizontal gap is Δx = x(t + Δt) − x(t) and the vertical gap is Δy = y(t + Δt) − y(t). The segment length is approximately √(Δx² + Δy²).
Step 4: Express gaps with derivatives. For small Δt, the definition of the derivative gives Δx ≈ (dx/dt)·Δt and Δy ≈ (dy/dt)·Δt. Substituting: segment length ≈ √(((dx/dt)·Δt)² + ((dy/dt)·Δt)²) = √((dx/dt)² + (dy/dt)²)·Δt.
Step 5: Form the infinitesimal length. In the limit as Δt approaches zero, this becomes the differential of arc length: \( ds = \sqrt{\left(\frac{dx}{dt}\right)^{2} + \left(\frac{dy}{dt}\right)^{2}}\,dt \).
Step 6: Integrate. Adding up all the infinitesimal pieces from t = a to t = b gives the total length: \( L = \int_{a}^{b} ds \), which is exactly the parametric arc length formula.
This derivation shows why the formula works: it is the Pythagorean theorem, shrunk to infinitesimal size and summed by integration.
Solved Examples of Parametric Arc Length
Example 1: Quarter Circle
Given: x(t) = 5cos(t), y(t) = 5sin(t), 0 ≤ t ≤ π/2.
Differentiate: dx/dt = −5sin(t), dy/dt = 5cos(t).
Form the speed: √((−5sin t)² + (5cos t)²) = √(25sin²t + 25cos²t) = √(25(sin²t + cos²t)) = √25 = 5.
Integrate: L = ∫₀π/2 5 dt = 5·(π/2) = 5π/2 ≈ 7.854.
Interpretation: A full circle of radius 5 has circumference 2π·5 = 10π. One quarter of that is 10π/4 = 5π/2, which matches our result exactly. The parameter interval [0, π/2] sweeps exactly one quarter of the circle.
Example 2: Straight-Line Parametric Path
Given: x(t) = 3t, y(t) = 4t, 0 ≤ t ≤ 2.
Differentiate: dx/dt = 3, dy/dt = 4.
Form the speed: √(3² + 4²) = √(9 + 16) = √25 = 5. The speed is constant because the motion is uniform along a straight line.
Integrate: L = ∫₀² 5 dt = 5·2 = 10.
Verification: The curve runs from (0, 0) to (6, 8). The distance formula gives √((6−0)² + (8−0)²) = √(36 + 64) = √100 = 10. The arc length formula agrees, as it must for a straight path.
Example 3: Cycloid Curve
Given: x(t) = r(t − sin t), y(t) = r(1 − cos t), 0 ≤ t ≤ 2π, with r > 0. A cycloid is the path traced by a point on the rim of a rolling wheel of radius r; one arch corresponds to one full revolution.
Differentiate: dx/dt = r(1 − cos t), dy/dt = r·sin t.
Form the speed: (dx/dt)² + (dy/dt)² = r²(1 − cos t)² + r²sin²t = r²(1 − 2cos t + cos²t + sin²t) = r²(2 − 2cos t) = 2r²(1 − cos t).
Using the identity 1 − cos t = 2sin²(t/2): speed² = 4r²sin²(t/2), so speed = 2r·|sin(t/2)| = 2r·sin(t/2) on [0, 2π].
Integrate: L = ∫₀2π 2r·sin(t/2) dt. Substitute u = t/2: L = 4r·∫₀^π sin u du = 4r·[−cos u]₀^π = 4r·(1 + 1) = 8r.
Interpretation: One complete cycloid arch has length exactly 8r, eight times the wheel's radius. Remarkably, this does not involve π at all.
Comparison Table
| Curve | Parameter Interval | Arc Length |
|---|---|---|
| Quarter circle, radius 5 | 0 ≤ t ≤ π/2 | 5π/2 ≈ 7.854 |
| Straight line (3t, 4t) | 0 ≤ t ≤ 2 | 10 |
| Cycloid arch, radius r | 0 ≤ t ≤ 2π | 8r |
How to Calculate Parametric Arc Length Manually
Follow this reusable procedure for any parametric arc length problem.
- Identify the component functions. Write down x(t) and y(t) clearly, and note the interval [a, b].
- Differentiate each component. Compute dx/dt and dy/dt using standard differentiation rules. Double-check trigonometric derivatives: the derivative of sin(t) is cos(t), and the derivative of cos(t) is −sin(t).
- Square and add. Compute (dx/dt)² + (dy/dt)². Look for chances to simplify using identities, especially sin²t + cos²t = 1.
- Simplify the square root. Try to write the expression under the root as a perfect square. If it simplifies to a constant or a simple function, the ∫ becomes easy.
- Set up the definite ∫. Write L = ∫ₐᵇ √(…) dt with the correct bounds.
- Evaluate. Find an antiderivative if one exists in elementary form, then apply the Fundamental Theorem of Calculus. If no elementary antiderivative exists, use a numerical method.
- Check the answer. Ask whether the number is reasonable. Compare against known cases: a straight segment should match the distance formula, and a circular arc should match the fraction of the circumference.
The most common simplification identities are sin²t + cos²t = 1, 1 − cos(2t) = 2sin²t, and 1 + cos(2t) = 2cos²t. Recognizing these under the square root is often the key step that makes an ∫ tractable.
Exact Arc Length vs Numerical Approximation
Some arc length integrals have clean antiderivatives, while others do not. Both situations are normal in calculus.
Exact solutions appear when the expression under the square root simplifies nicely. Circles, lines, and cycloids are classic cases where the algebra collapses and the ∫ evaluates to a simple closed form. When this happens, you get an exact answer like 5π/2 or 8r.
Numerical approximation is needed when the integrand has no elementary antiderivative. This is common: even simple-looking curves like y = x³ between two points, or an ellipse parameterized by (a·cos t, b·sin t), lead to integrals that cannot be expressed with basic functions. The ∫ still exists as a number; it just cannot be written in closed form.
Numerical integration estimates the definite ∫ by sampling the function at many points and combining those samples with weights. Simpson's rule is one popular method: it approximates the curve of the integrand with parabolas over pairs of subintervals, which is remarkably accurate for smooth functions. Doubling the number of subintervals typically reduces the error dramatically.
Approximation accuracy depends on how wiggly the integrand is and how many sample points are used. Smooth, gentle integrands converge quickly; integrands with sharp corners or rapid oscillation need more subdivisions. If your result changes only in the far decimal places when you refine the computation, you can trust it.
This page's calculator handles both cases: it presents exact symbolic results when the ∫ resolves cleanly and falls back to numerical evaluation otherwise.
Common Mistakes When Calculating Parametric Arc Length
- Using the wrong parameter interval. The bounds a and b are t-values, not x-coordinates. For x(t) = 5cos(t), the interval [0, π/2] is an angle range, not a horizontal range. Mixing these up measures the wrong portion of the curve.
- Forgetting to square the derivatives. The formula needs (dx/dt)² + (dy/dt)² under the root. Adding unsquared derivatives gives a meaningless quantity that can even be negative.
- Differentiating trigonometric functions incorrectly. The derivative of cos(t) is −sin(t), with the negative sign. Dropping it changes the speed computation (though squaring later hides the sign, it matters in intermediate steps).
- Assuming displacement equals path length. A curve that goes out and back has positive arc length but possibly zero net displacement. Always integrate the speed, never the signed velocity components.
- Measuring multiple revolutions unintentionally. On a periodic curve like a circle, the interval [0, 4π] traces the circle twice and doubles the length. Restrict the interval to exactly the portion you want.
- Entering expressions the calculator cannot parse. Implicit multiplication like
5tor a bareπcharacter may fail. Write5*tandπ. - Ignoring non-smooth points. At a cusp or corner, the derivative may be undefined or zero in a way that breaks the formula. Split the interval at such points and compute each smooth piece separately.
- Confusing orientation with length. Traversing a curve backward (from b to a) gives the same geometric length as traversing it forward, because the speed involves squared derivatives. Direction does not change distance.
Real-World Applications of Parametric Arc Length
Engineering and manufacturing. A CNC milling machine follows a programmed tool path described by parametric equations. Knowing the total path length helps estimate machining time and material wear. Similarly, the curved edge of a manufactured part can be measured from its CAD model using the same mathematics.
Robotics. When a robot arm moves its end effector along a planned trajectory, engineers parameterize the path and compute its length to predict travel time and energy use. A welding robot tracing a curved seam needs the seam's exact length to set the correct welding speed.
Computer graphics and animation. Characters and cameras in animated films move along parametric spline curves. Animators use arc length to control speed: without it, an object would speed up and slow down unnaturally as the parameterization stretches and compresses. Converting to arc-length parameterization gives uniform motion.
Physics. A projectile with air resistance, a planet in an elliptical orbit, or a charged particle in a magnetic field all follow paths naturally described by parametric equations. The distance traveled along such a path is an arc length problem.
Computer-aided design. Architects and product designers work with Bézier and spline curves constantly. Estimating curve lengths matters for material quantities: the length of a curved handrail, a decorative trim, or a bent pipe all come from parametric arc length computations.
Parametric vs Cartesian vs Polar Arc Length
Curves can be described in several coordinate systems, and each has its own arc length formula. Choose the one matching how your curve is given.
| Representation | Required Inputs | Formula | Best Use Case |
|---|---|---|---|
| Parametric: (x(t), y(t)) | Two functions, parameter bounds a, b | ∫ₐᵇ √((dx/dt)² + (dy/dt)²) dt | Motion paths, loops, curves that fail the vertical-line test |
| Cartesian: y = f(x) | One function, x-bounds | ∫ₐᵇ √(1 + (dy/dx)²) dx | Simple graphs where y depends on x |
| Polar: r = r(θ) | One function, angle bounds α, β | ∫ᵅᵝ √(r² + (dr/dθ)²) dθ | Spirals, cardioids, rose curves centered at the origin |
Use the polar arc length calculator when your curve is given as r(θ), and the main arc length calculator for Cartesian functions. If your curve has a z-component, the parametric formula extends naturally to three dimensions: add (dz/dt)² under the square root. See the 3D arc length calculator for space curves.
Tips for Getting Reliable Arc Length Results
- Isolate the segment you want. On periodic curves, choose bounds that cover exactly one traversal of the desired portion. When in doubt, sketch the curve first.
- Check the parameter domain. Make sure both x(t) and y(t) are defined and smooth on the entire interval. Watch for division by zero, square roots of negative numbers, and logarithms of non-positive values.
- Verify simple cases by hand. Before trusting a complicated result, test the calculator on a case you can check: a line segment (distance formula) or a circular arc (fraction of circumference).
- Keep units consistent. The output inherits the units of your coordinates. If x and y are in meters, the arc length is in meters.
- Watch for repeated traversal. If the computed length seems too large, the parameterization may retrace part of the curve. Shorten the interval or reparameterize.
- Compare against known formulas. A result for a full circle should be close to 2πr; a straight diagonal should match the distance formula. Large disagreements signal an input error.
- Respect numerical limits. Very long intervals, highly oscillatory functions, or near-singular integrands can degrade numerical accuracy. Split difficult intervals into smaller pieces when possible.
Parametric Arc Length FAQs
How do you find the arc length of parametric equations? +
Differentiate x(t) and y(t) with respect to t, square both derivatives, add them, take the square root to get the speed, then integrate from the start parameter a to the end parameter b. The formula is L = ∫ₐᵇ √((dx/dt)² + (dy/dt)²) dt.
Can parametric arc length be calculated without converting to Cartesian form? +
Yes, and you should not convert. The parametric formula works directly on x(t) and y(t). Converting to Cartesian form y = f(x) is often impossible (for loops or self-intersecting curves) and never necessary for arc length.
How do you choose the correct parameter interval? +
The interval [a, b] must cover exactly the portion of the curve you want to measure, no more and no less. For a full circle parameterized by angle, use [0, 2π]. For a curve traced twice, halve the interval to measure it once. Sketching the curve helps confirm the bounds.
Why do some parametric arc length integrals require numerical methods? +
Many speed expressions have no elementary antiderivative, so the definite integral cannot be written in closed form with basic functions. The integral still has a definite numerical value, which methods like Simpson's rule approximate to high accuracy.
Does changing the direction of a parametric curve change its length? +
No. Reversing direction replaces t with a decreasing parameter, but the speed √((dx/dt)² + (dy/dt)²) is unchanged because both derivatives are squared. Geometric length depends on the path, not the direction of travel.
What is the difference between velocity and speed in the arc length formula? +
Velocity is the vector (dx/dt, dy/dt), which has direction. Speed is its magnitude √((dx/dt)² + (dy/dt)²), a nonnegative scalar. Arc length integrates speed because distance accumulates regardless of direction; integrating velocity components would allow cancellations.
How do you verify an arc length calculator result? +
Test it on cases with known answers: a straight segment should match the distance formula, and a circular arc should equal the corresponding fraction of 2πr. Also check that the result is positive, has sensible magnitude, and barely changes when you refine the computation.